
■ IAAC / RESPONSIVE SYSTEMS / EXPERIMENT 001
ONE
MOTION.
TWO
OUTCOMES.
[ SYSTEM STATUS : ACTIVE ]
[ STRUCTURE : TENSILE ]
[ ACTUATION : CABLE ]
[ RESPONSE : ADAPTIVE ]
[ CONTROL : COMPUTATIONAL ]
[ VERSION : PROTOTYPE 03 ]
↗ STRUCTURE AS SOFTWARE
FIG 00 / MOTION STUDIES — PROTOTYPE DOCUMENTATION
01 /// SYSTEM HYPOTHESIS
STATIC
IS NOT
ENOUGH.
Tensile structures are commonly used for shading and sheltering outdoor spaces, offering broad coverage with lightweight materials.
However, their typically fixed forms limit their ability to respond to changing weather and the needs of the people beneath them.
reRavel explores an alternative: a tensile structure whose shape and openings respond to climatic conditions, ensuring comfort as a product of computer programming.
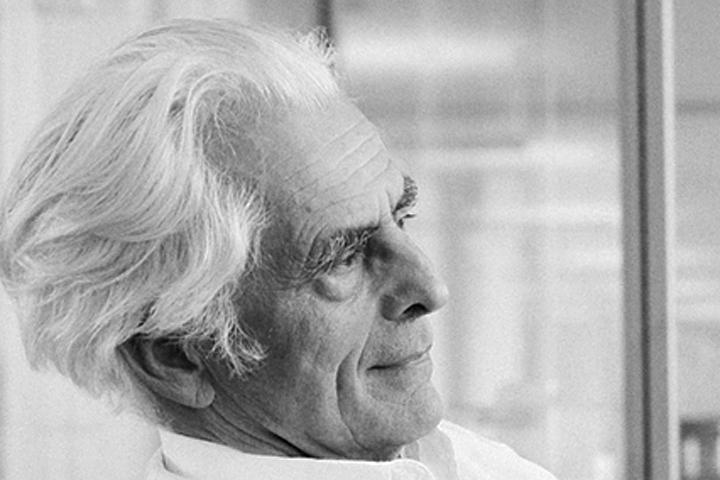
FIG 01.01 / FREI PAUL OTTO REVOLUTIONIZED MODERN TENSILE AND MEMBRANE STRUCTURES
02 /// KINEMATIC DEVELOPMENT
PULL. TEST.
RECONFIGURE.
MOTOR [01]
↓
SPINDLE [02]
↓
CABLE A ↗
CABLE B ↙
↓
CANOPY [Δ]
One motor. Two opposing cable movements.
Inspired by Frei Otto’s tensile structures, the project combines a flexible canopy with a rigid spindle mechanism, motorized cables, and suspended weights to adjust its shape and openings.
As the motor winds and unwinds the cables, opposing tension allows the canopy to rise, fall, and adjust its openings. One motion, two outcomes.
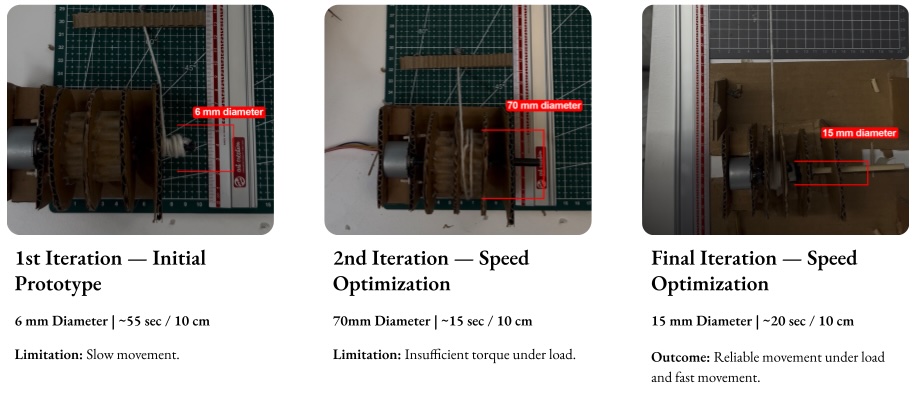
[ PHYSICAL ITERATIONS / 01—03 ]
The design process developed simultaneously through physical prototypes, digital modeling, and computational design. Our first iteration used a single cable driven by a motor, dragging the cable rather than winding it onto a spindle.
The second introduced a dual-cable arrangement with a double spindle, simultaneously winding one side while releasing the other. The final prototype combined this approach with weighted tension, two-flag position detection, and fully integrated control electronics, hardware, and wiring.
Further prototyping revealed the importance of balancing movement, speed, and torque. Three spindle diameters were tested to achieve reliable movement under load.
[ SPINDLE DIAMETER / PERFORMANCE DATA ]
TEST_001
06 mm
55 SEC / 10 CM
Slow movement
TEST_002
70 mm
15 SEC / 10 CM
Insufficient torque
TEST_003 / SELECTED
15 mm
20 SEC / 10 CM
Reliable under load ■
03 /// COMPUTATIONAL GEOMETRY
[ PARAMETRIC STUDY / 06 AXES ]
SIX AXES.
VARIABLE
FORM.
A Grasshopper animation explores geometric variation through a six-axis configuration.
The digital study illustrates the potential for multiple points of movement to generate changing spatial geometries. It provides a computational exploration alongside the physical cable-driven prototype.
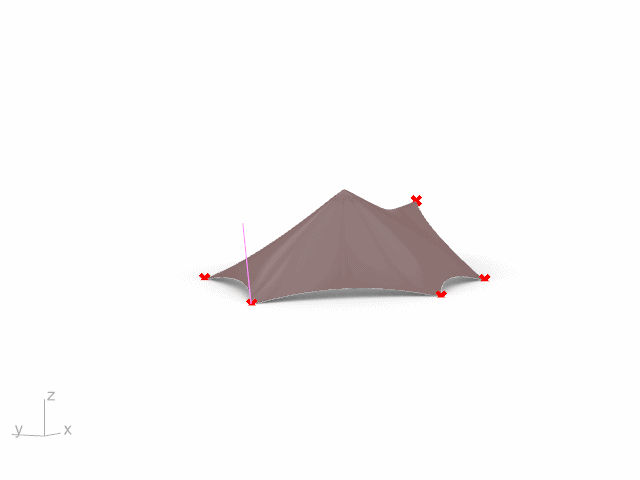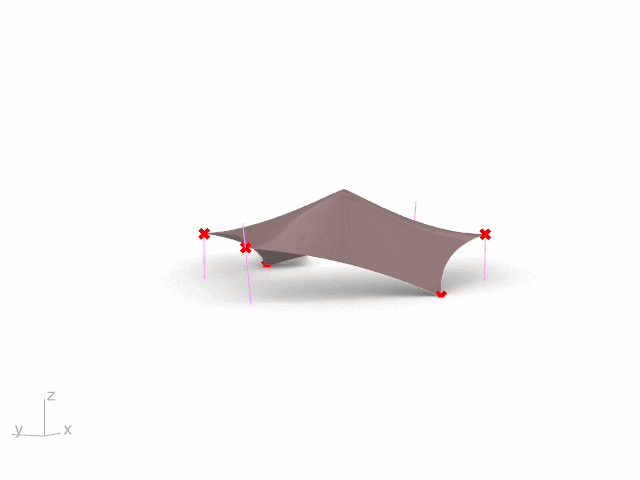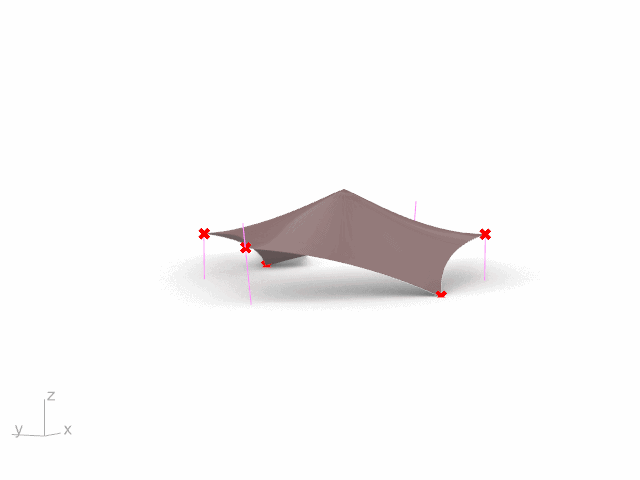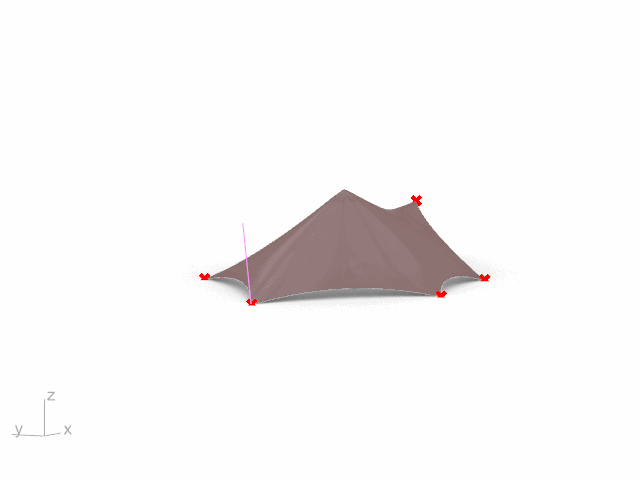
FIG 03.01 / GRASSHOPPER / SIX-AXIS STUDY
04 /// INTEGRATED SYSTEMS
FROM DATA
TO SPACE.
ENVIRONMENT
↓
INPUT
↓
CONTROL
↓
ACTUATION
↓
GEOMETRY
The integrated-systems diagram frames reRavel as an architectural system rather than an isolated mechanical object.
Its conceptual organization connects environmental conditions, sensing, computational control, cable actuation, and the resulting changes in canopy geometry.
While the current prototype demonstrates motorized movement and position detection, the broader system proposes responsive behavior driven by environmental information.
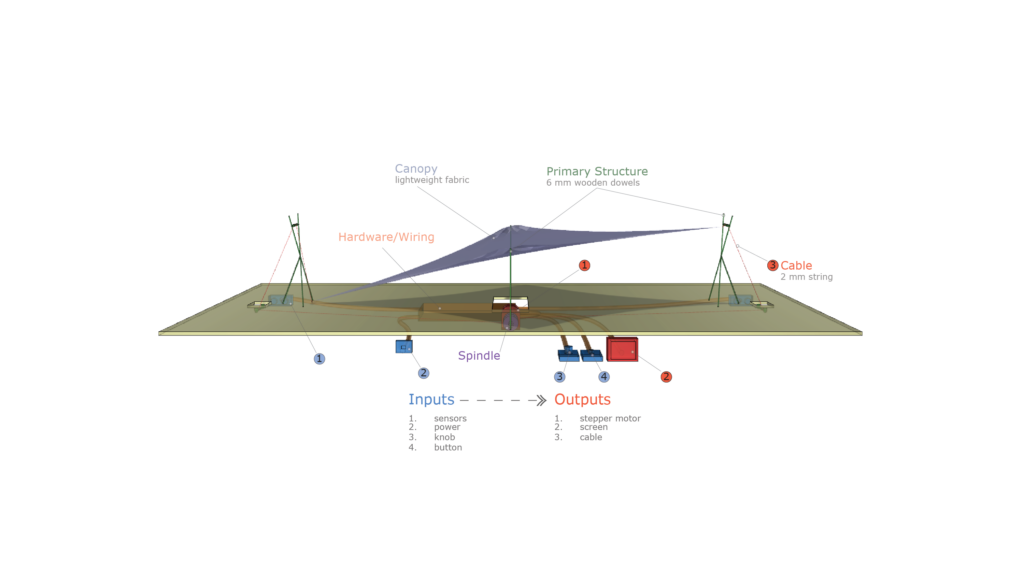
FIG 04.01 / INTEGRATED SYSTEMS — CONCEPTUAL FRAMEWORK
05 /// HARDWARE ANATOMY
THE MACHINE
BELOW.
Fabricated on a 40 × 70 cm grid, the prototype integrates the canopy and primary structure above a solid floor plate, with the motor, electronics, and wiring below.
Openings allow cables to pass through the plate while revealing the mechanism to users. Cable clips keep the strings aligned during operation.
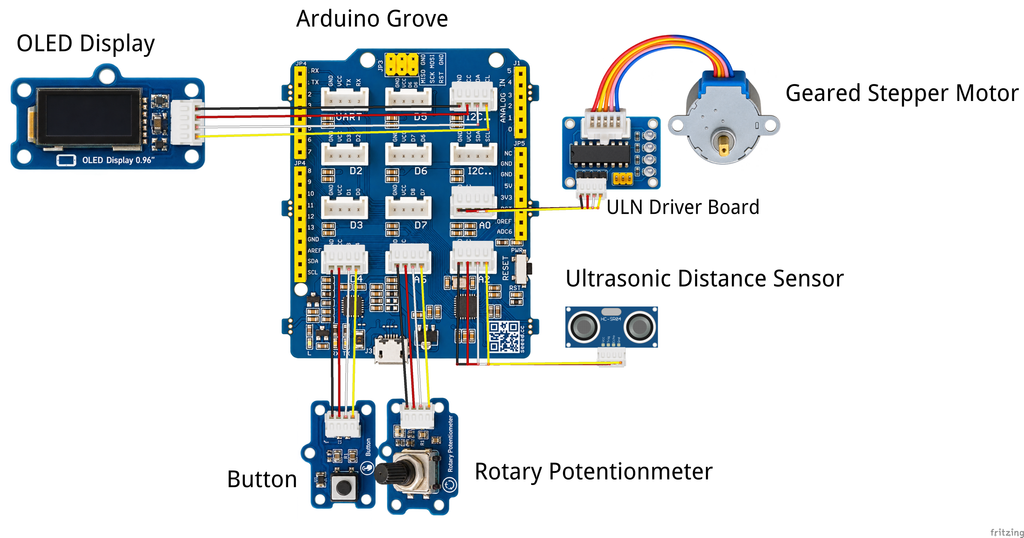
FIG 05.01 / ELECTRONIC ASSEMBLY
CONTROL STACK [05]
A Grove microcontroller coordinates a stepper motor through a ULN2003 driver. A rotary potentiometer controls speed and direction, a push button switches operation on and off, and an OLED screen displays system status. An ultrasonic sensor provides distance detection.
06 /// CONTROL LOGIC
IF / THEN
MOVE.
INPUT → PROCESS → MOTION → FEEDBACK
01 / Button
Toggles the motor on and off, debounced so one press counts once. When the motor turns on, the dial’s position sets the starting direction.
02 / Potentiometer
Sets speed and direction. The center dead zone stops the motor, while moving the dial away from center increases speed.
03 / Flag Detection
The ultrasonic sensor detects flags on the cable. A flag within 8 cm reverses the motor. The flag must move beyond 11 cm before it can trigger again, with a 20-second cooldown after each reversal.
04 / Serial Monitor
Displays motor state, flag detection, direction changes, and sensor readiness at 9600 baud.
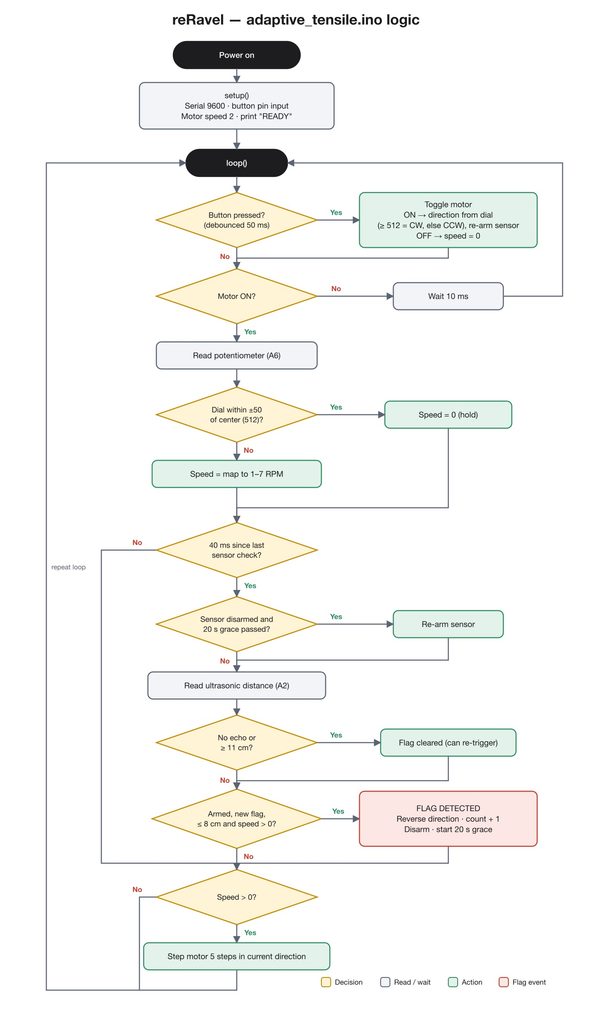
FIG 06.01 / BEHAVIORAL CONTROL FLOW
07 /// ARCHITECTURAL PROJECTIONS
BEYOND
THE
PROTOTYPE.
From physical prototype to architectural possibility.
The following visualizations explore reRavel beyond its physical model, imagining the adaptive tensile system at an architectural scale.
RENDER_001 / SCENARIO
RENDER_002 / SCENARIO
RENDER_003 / SCENARIO
FIG 07.01—03 / SPECULATIVE ARCHITECTURAL APPLICATIONS
[ POTENTIAL SPATIAL APPLICATIONS / 03 ]
01 / Terrace Shade Cover
The canopy provides shading for the terrace that adjusts to the direction of sunlight.
02 / Concert Venue
The canopy frames a sheltered performance space, adjusting its shape to accommodate different events and spatial needs.
03 / Community Garden
Flexible openings regulate sunlight over planting and eating areas, supporting plant growth and community gatherings.
08 /// FUTURE SYSTEMS
FORM IS
NOT
FINAL.
reRavel demonstrates how a single motor can coordinate two cable outputs, pulling one side while releasing the other so that suspended weights provide the opposing movement.
Future development would introduce independent control of multiple canopy vertices and environmental sensors, enabling more complex geometries and responses to wind, movement, sound, humidity, and more.
These capabilities could support varied applications, from shaded gardens and dining terraces to sheltered bathing spaces and concert venues.
END OF DOCUMENTATION
reRavel_
[ OPEN SOURCE / EXPERIMENTAL ARCHITECTURE ]
IAAC / 2026 / SYSTEM EXPERIMENT 001
